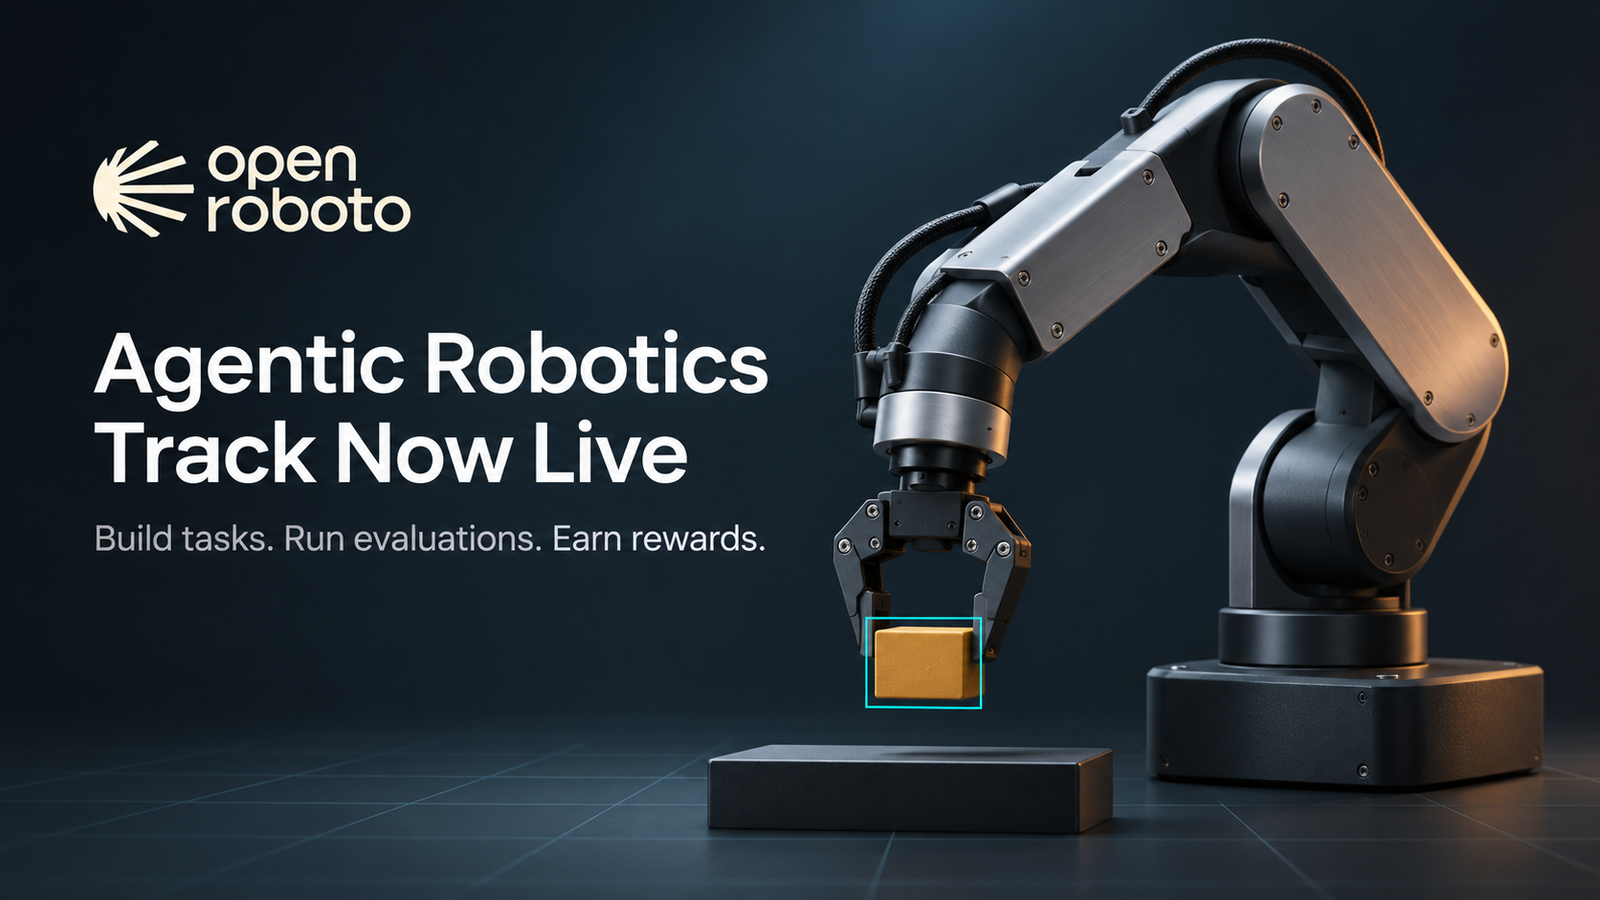
An AI model can explain how to pick up a cup. Give it control of a robot arm, and it has to judge where the cup is, decide where to grip it, and lift it without tipping it over.
OpenRoboto (SN80) has launched its Agentic Robotics Track to see how well frontier models handle those decisions in simulation.
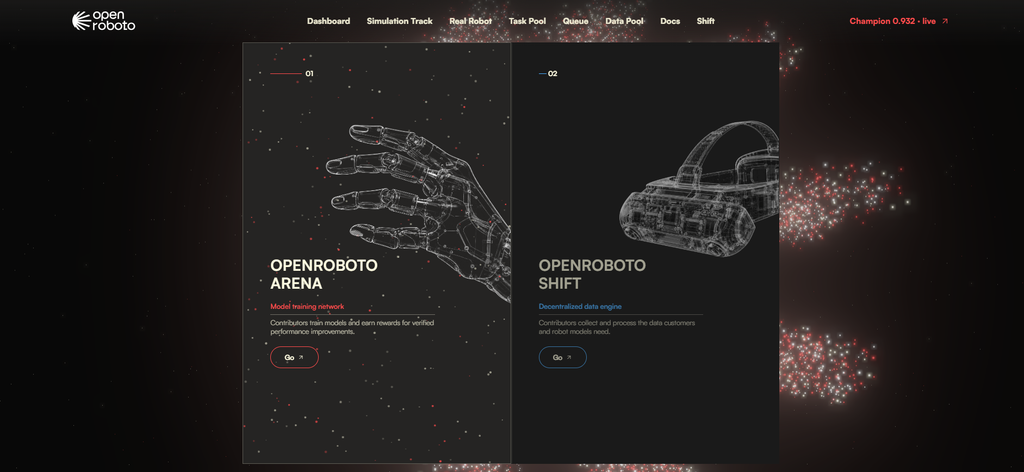
OpenRoboto (SN80) develops open tools and benchmarks for robot intelligence. Miners can start by designing tasks and will be able to run evaluations when the second track opens. They can contribute to either track or both.
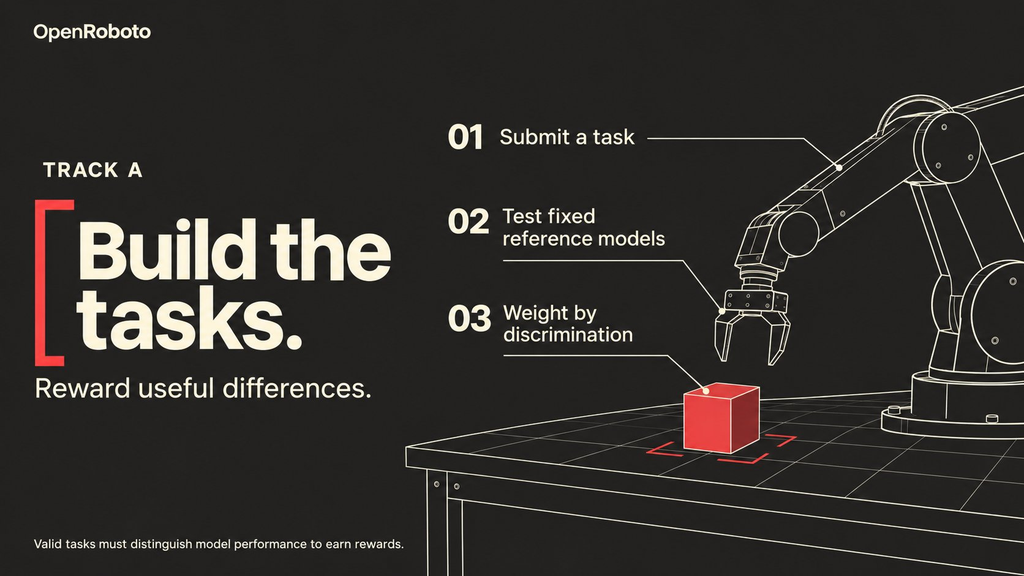
In Track A, miners submit a simulated scene, clear success criteria, and a demonstration of how to complete the task. Evaluators check that the task is valid and can be reproduced before testing it with the same two reference models.
Validators give more weight to tasks that consistently reveal a gap between the models’ performance.
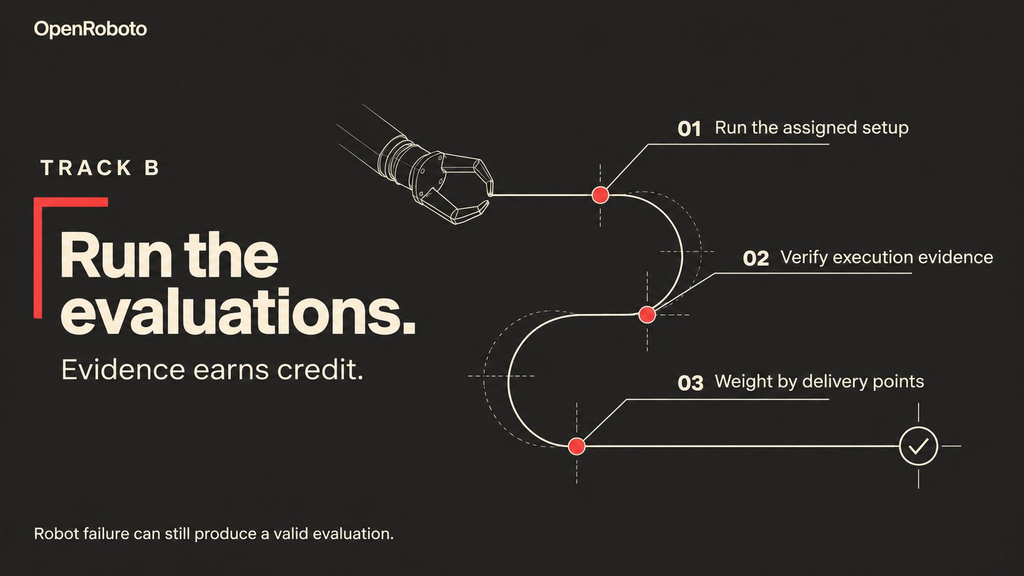
In its upcoming Track B, miners will claim jobs that specify the task, the model, the tools it can use, and the budget for the run. They’ll submit the outcome alongside evidence that the evaluation ran as specified. A miner can earn rewards for a verified run even if the model fails the task.
The most revealing moment in a cup lift might come when the cup slips. Does the model adjust its grip, try again, or keep moving as if it still has the cup?
A task designed around that moment can show how well a model responds when its first move goes wrong.
➛ Join SN80’s Agentic Robotics Track Here.
Enjoyed this article? Join our newsletter
Get the latest TAO & Bittensor news straight to your inbox.
We respect your privacy. Unsubscribe anytime.
Enjoyed this article?
Join our newsletter
Get the latest TAO & Bittensor news straight to your inbox — every morning before markets open.
No comments yet — be the first.