A new AI model has delivered efficient performance in robot control, beating larger models on both speed and cost.
OpenRoboto (SN80) tested Jev from TypeSafe AI against two heavyweight language models in a physics simulation, giving all three systems the same task.
Each model had to control a virtual robot arm, pick up an apple, and place it carefully on a plate.
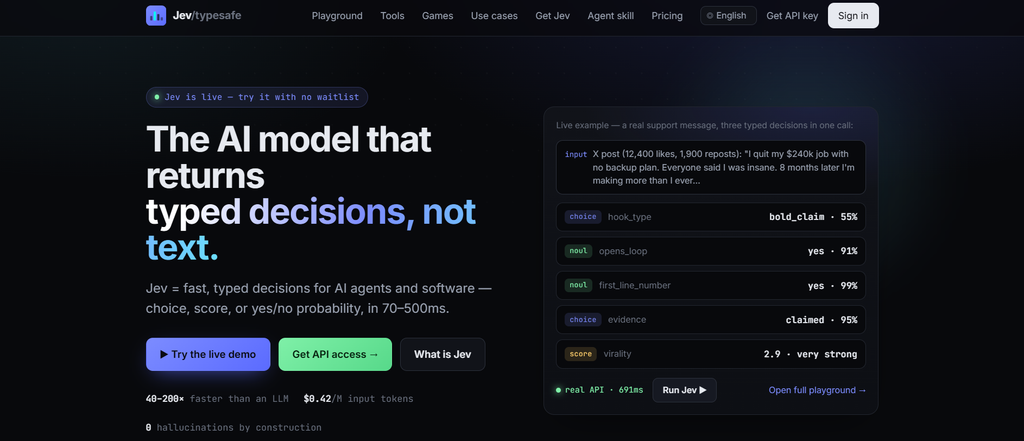
For context, Jev is a new AI model from TypeSafe AI, built to make fast decisions that software can act on. Unlike chatbots that generate text, Jev returns clear answers such as choices, scores, or probabilities.
It can be used for tasks like sorting customer requests, detecting risky content, and helping robots decide what to do next.
OpenRoboto (SN80) runs an open robotics competition on Bittensor where developers build and test models designed to control robots. The project gives researchers a public environment for comparing how different AI systems translate instructions into physical actions.
Jev was tested under the same conditions as the competing models, making the comparison focused on performance, and not on different hardware or instructions.
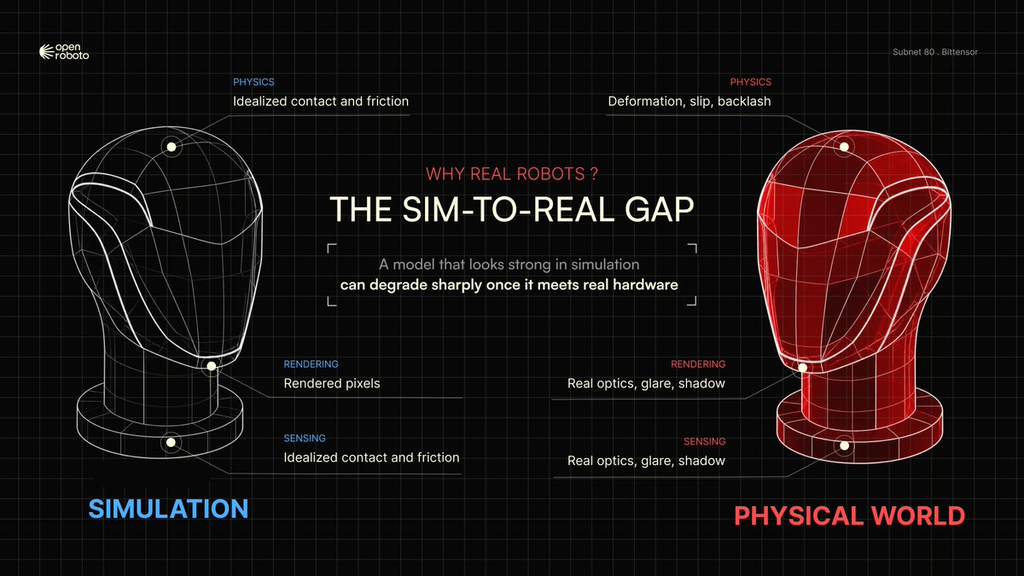
The results showed Jev completing the task for roughly 1/315th of GPT-6 Astra’s API cost and in about 26% of its wall time.
Jev finished the apple placement in 181.847 seconds of actual wall time, while GPT-6 Astra took 707.274 seconds despite completing the same task.
GPT-4.1 mini reached the 160-cycle limit without successfully placing the apple, giving Jev a clear advantage in both execution speed and resource efficiency.
The experiment also gives developers access to the actual process, not just a final success rate. OpenRoboto published the recordings and supporting material so builders can inspect how each model handled the robot’s movements.
Every system received the same basic instruction and operated the same virtual robot, giving the comparison a common baseline.
Jev does not establish that smaller models are universally better at robotics, but the numbers demonstrate why efficiency matters inside robot control loops.
A model that can make useful decisions faster and at a fraction of the cost can support far more repeated interactions before expenses become restrictive.
OpenRoboto’s test therefore puts a concrete result behind the idea that capable robot intelligence does not always require the largest language model.
➛ View OpenRoboto’s Jev GitHub Deck Here.
Enjoyed this article? Join our newsletter
Get the latest TAO & Bittensor news straight to your inbox.
We respect your privacy. Unsubscribe anytime.
Enjoyed this article?
Join our newsletter
Get the latest TAO & Bittensor news straight to your inbox — every morning before markets open.
No comments yet — be the first.